/01
Fluidic artificial muscles
Electrically driven fiber actuators — modular and scalable — for robots that move like living bodies.
We move intelligence from software into matter: pumps, muscles and fibers that generate motion from electricity alone — no motors, compressors or rigid parts.
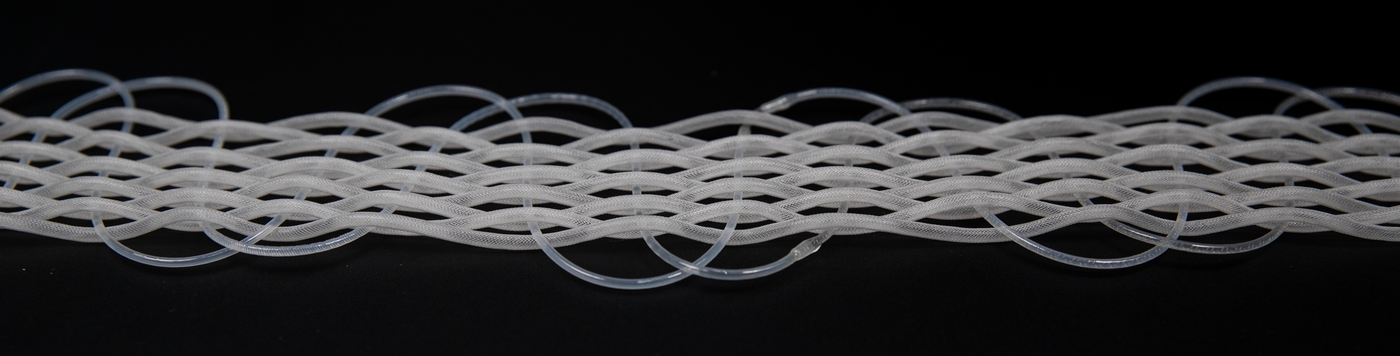
With the MIT Media Lab: a new class of fiber-format artificial muscles that integrates fiber pumps and McKibben actuators in a closed circuit. Electric, silent and untethered, they pair up in antagonistic configurations like biological muscle and, thanks to bias pressure, reach power densities comparable to skeletal muscle.
Kilic Afsar, Pupillo, Vitucci, Babatain, Ishii, Cacucciolo.
Learn more →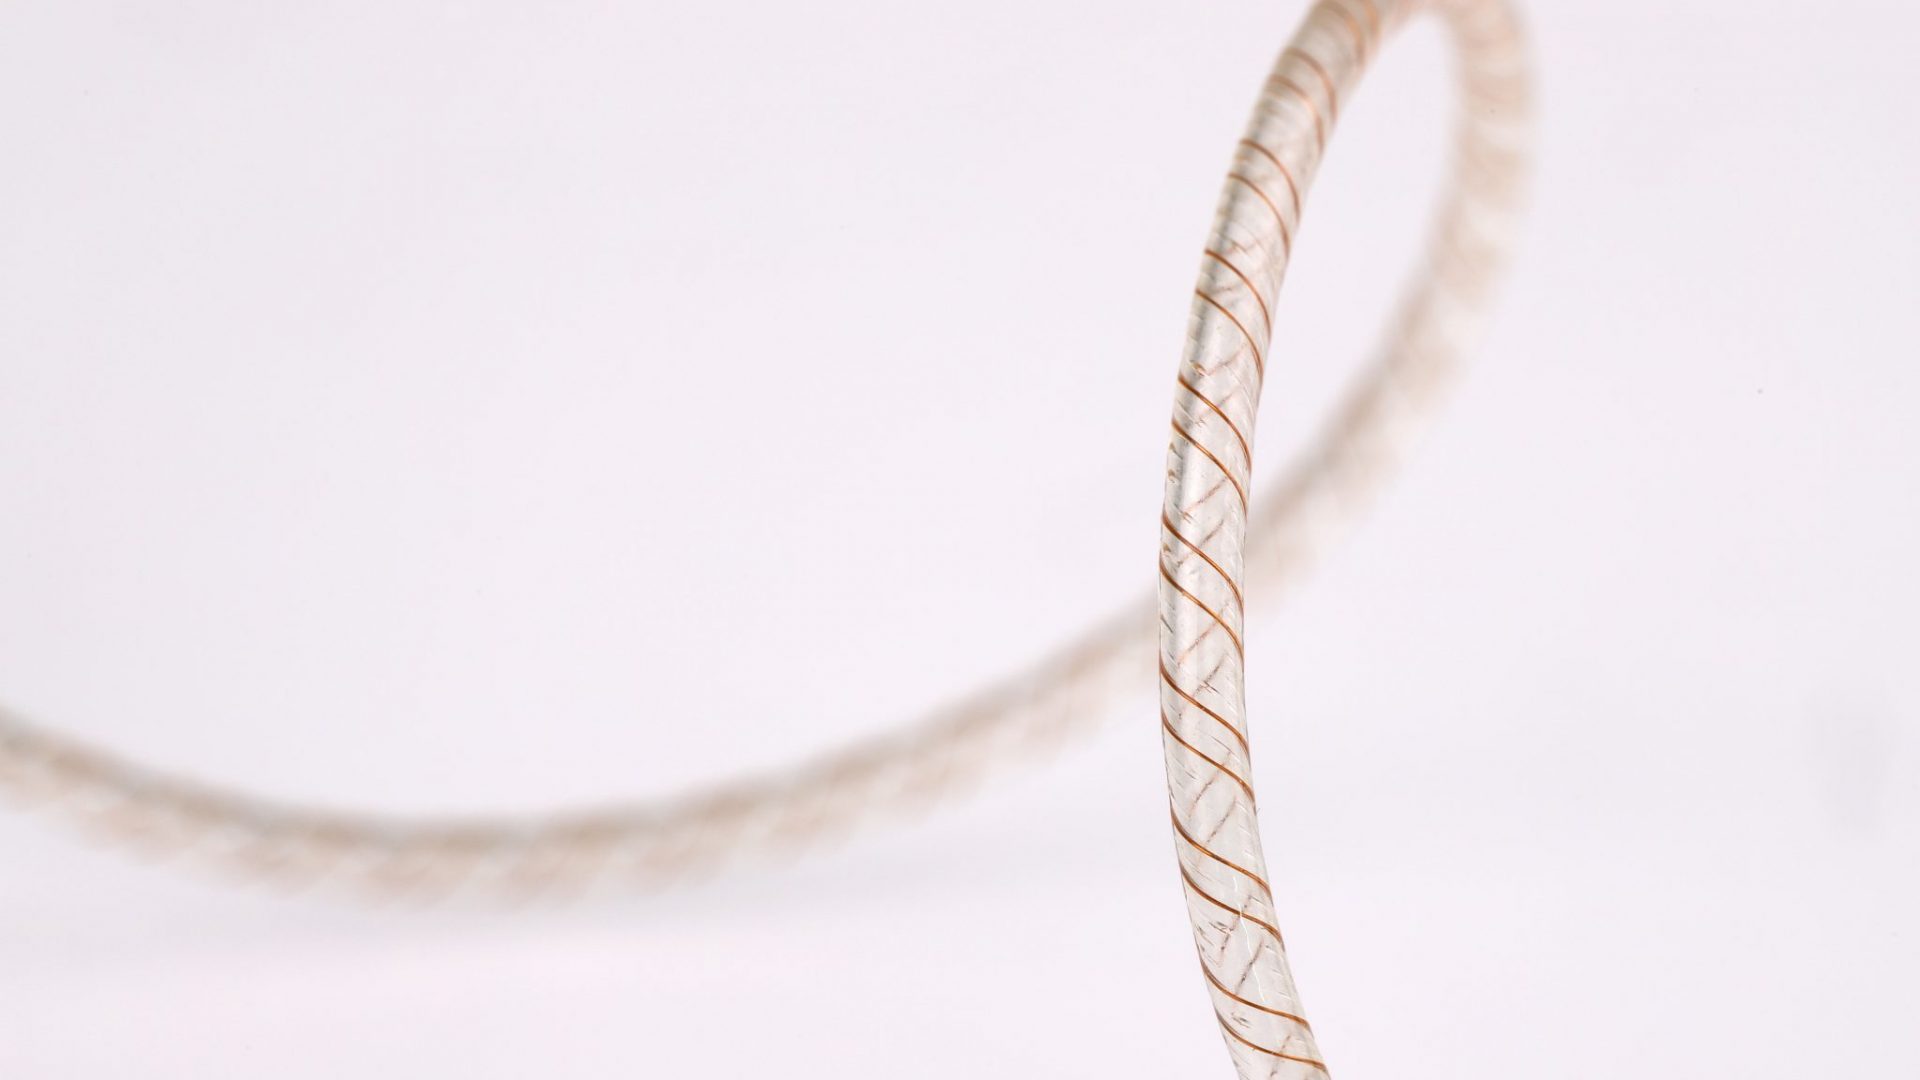
The pump becomes a fiber: a soft tube 2 mm in diameter with helical electrodes embedded in the wall, produced continuously and weavable like a thread. It integrates pressurised fluidic circuits directly into garments and textiles, for thermoregulation, muscle support and haptic feedback.
Smith, Cacucciolo, Shea.
Learn more →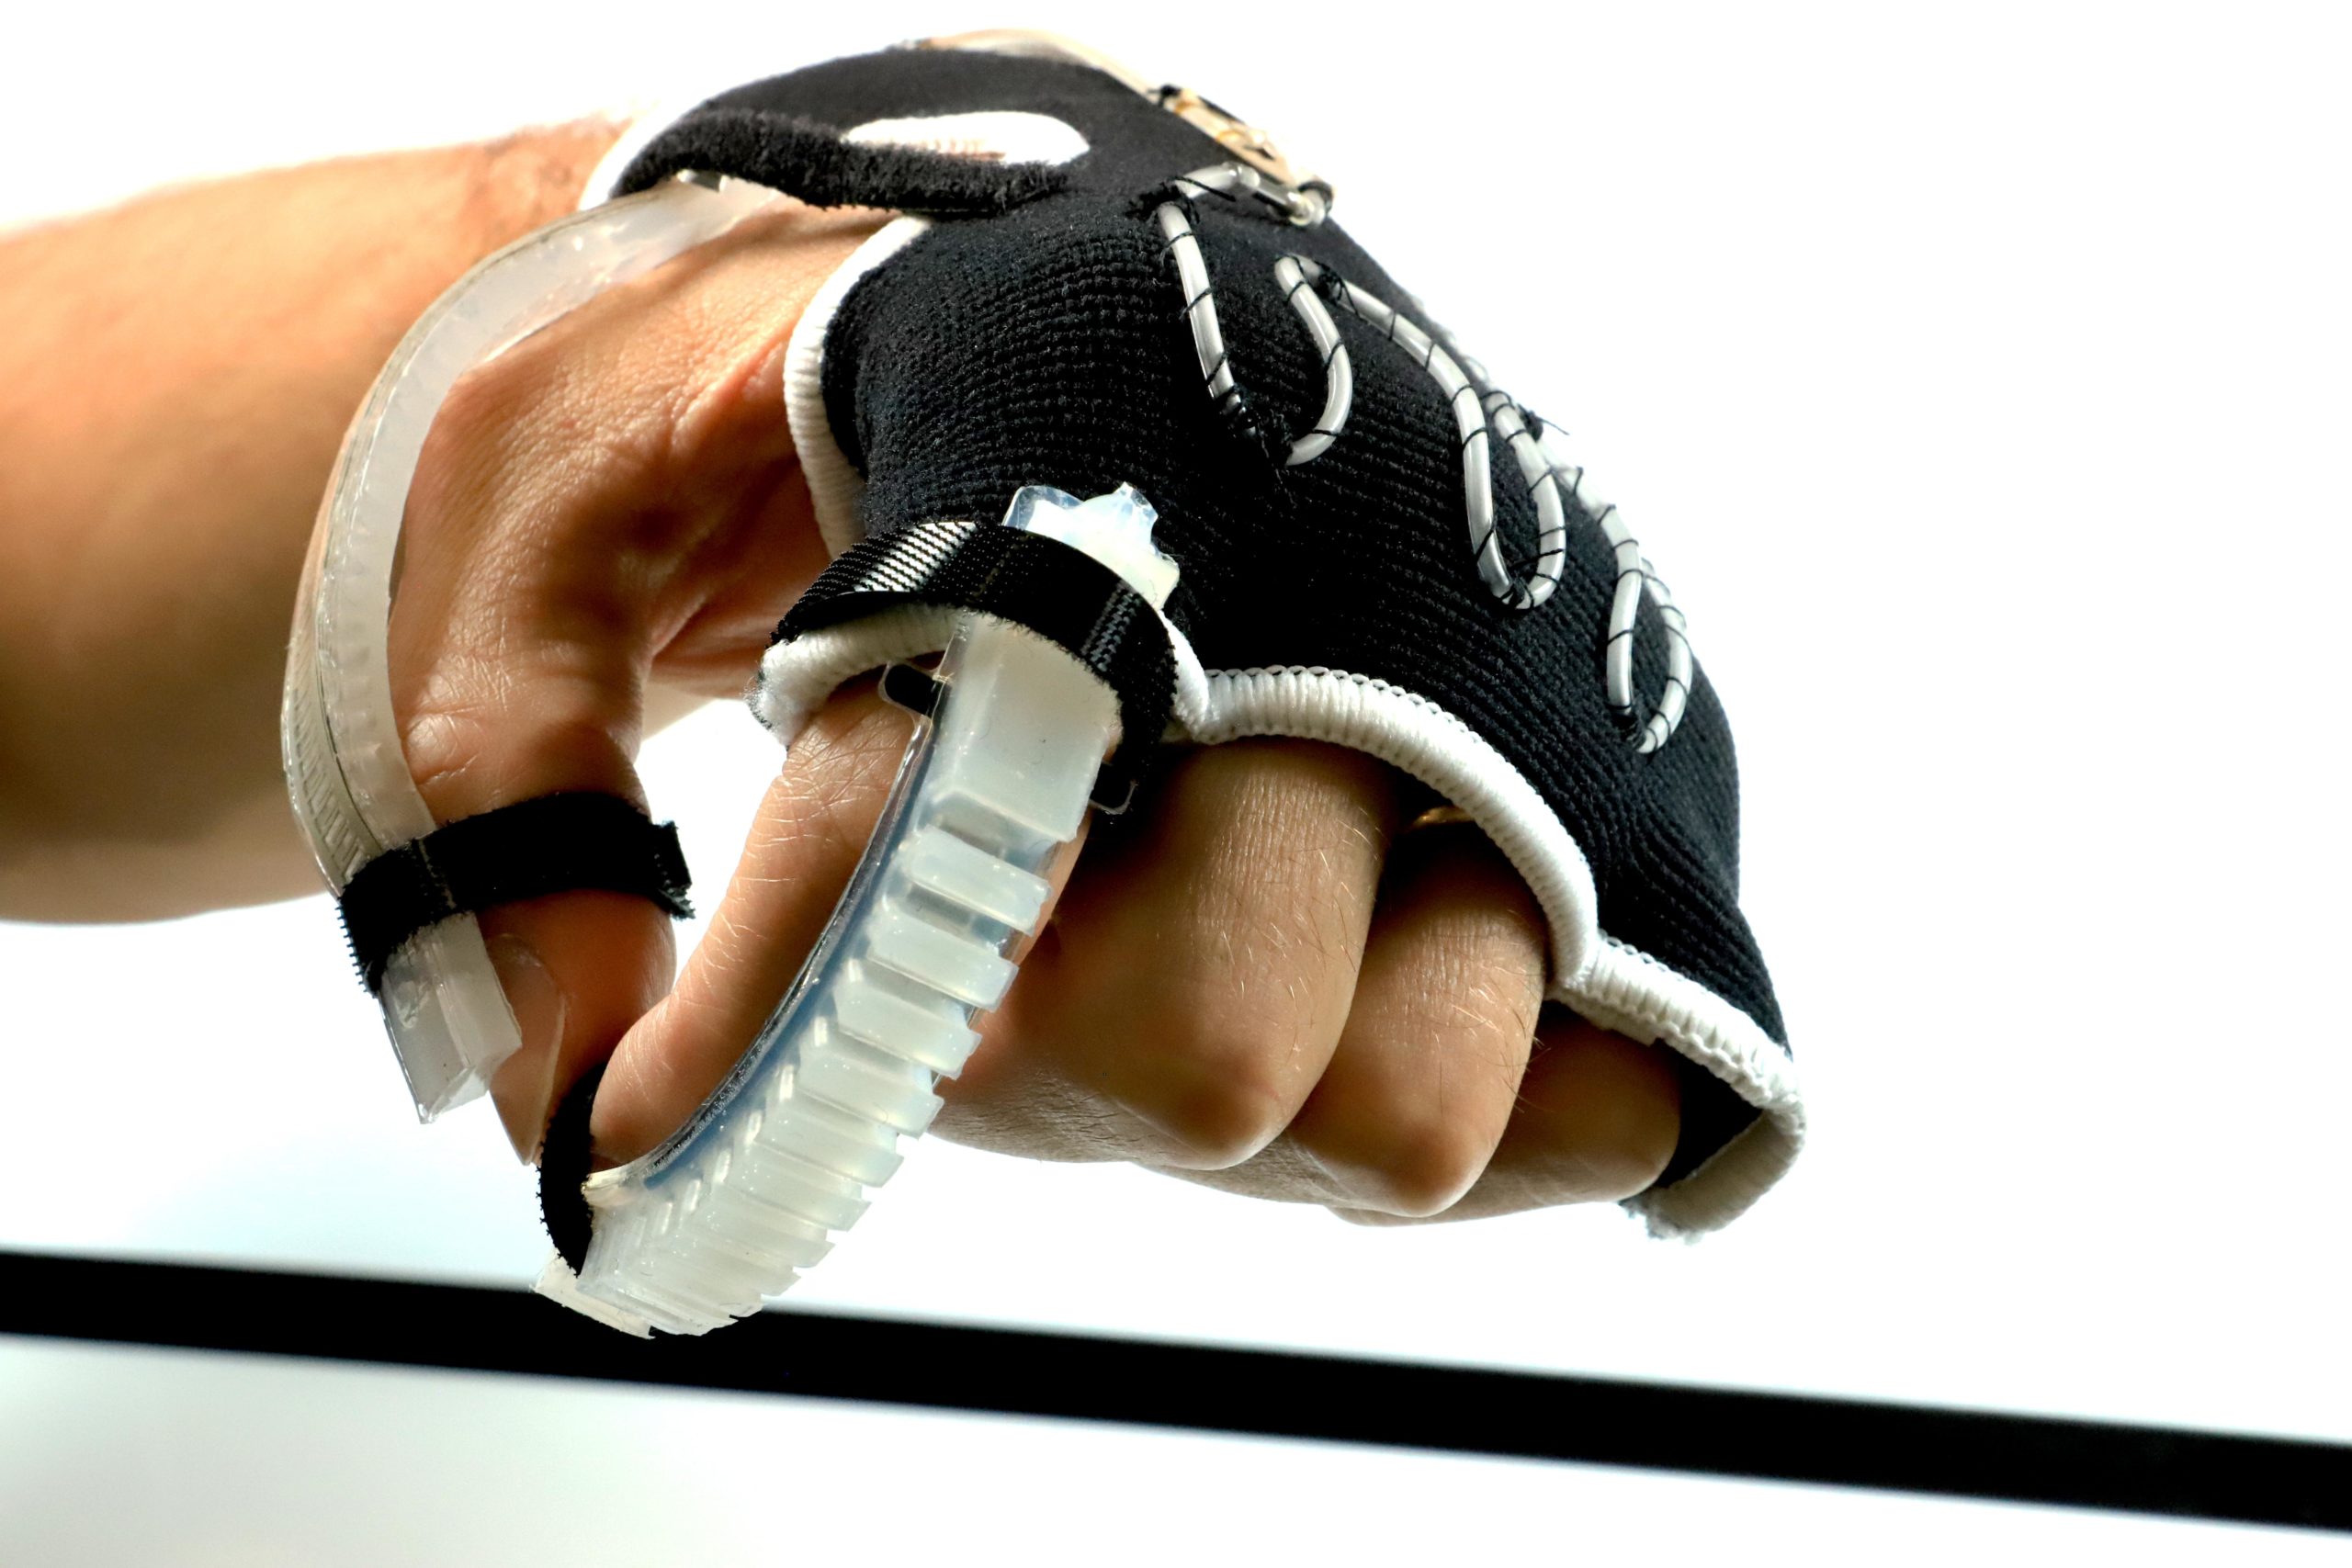
The world's first fully soft, stretchable pumps: they convert electricity directly into flow through electrohydrodynamics, with no moving parts. The result that opened the way to fluidic muscles free of external infrastructure.
Cacucciolo, Shintake, Kuwajima, Maeda, Floreano, Shea.
Learn more →Electrically driven fiber actuators — modular and scalable — for robots that move like living bodies.
Wearable tactile feedback for telemanipulation: working with your hands thousands of kilometres away.
Fluidic circuits woven into garments that actively heat or cool the wearer.
Prosthetics and end-effectors driven by muscle fibers, with the linear configuration of natural muscle.
Contenuti offline — database non raggiungibile