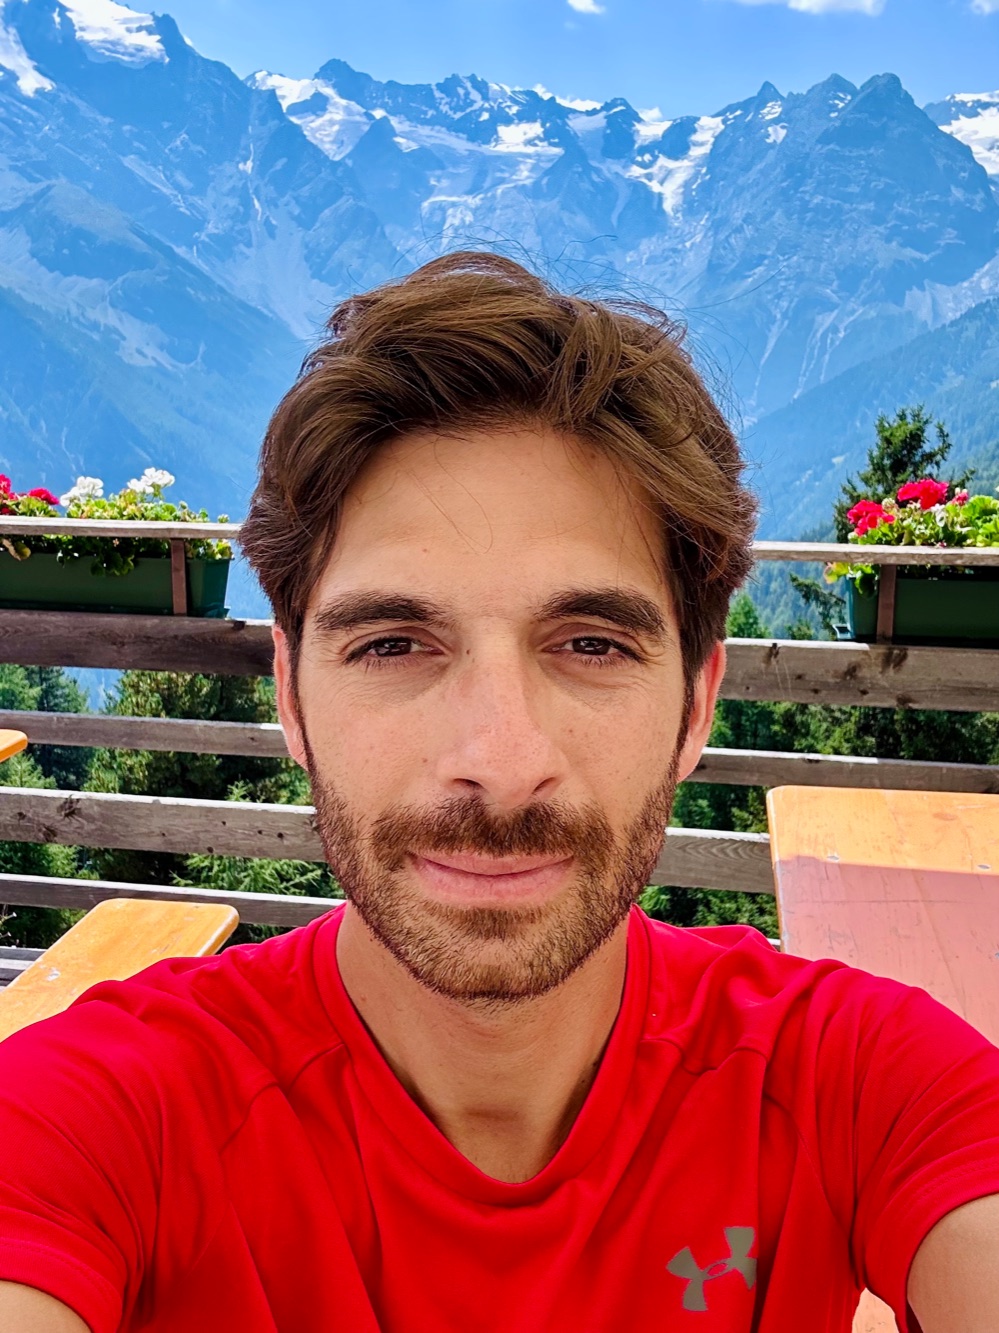
Current positions
- Since 2023Associate ProfessorPolitecnico di Bari — Department of Mechanics, Mathematics and Management (DMMM)

- Since 2022Founder and President
Experience
- 2023ERC Starting Grant
- 2022 – 2026Research Affiliate
- 2020 – 2021BRIDGE Fellow
- 2017 – 2021
- 2017PhD in BioRobotics
Teaching
- Since 2023MechatronicsMaster degree in Mechanical Engineering — second year, first semester
- Since 2024Applied Mechanics, second moduleMaster degree in Automation and Robotic Engineering — first year, second semester
Research highlights
Electrofluidic Fiber Muscles
Electrically driven artificial muscles with a power density comparable to skeletal muscle (50 W/kg), driven by EHD fiber pumps in a closed circuit. 20% strain, response under 0.3 s.
Read more →Fiber pumps for wearable fluidics
The first pumps in the form of 2 mm-thick rubber tubes: the tube is the pump, enabling fluidics for thermally active clothing and soft robots.
Read more →Stretchable pumps for soft machines
World-first fully stretchable pumps, enabling thermally active wearables and fluidic artificial muscles.
Read more →Peeling in electroadhesion soft grippers
Strong and fast grippers for delicate objects, enabled by understanding the peeling mechanics of electroadhesion.
Read the paper ↗Soft Robotic Grippers
A review of the fast-growing field of soft robotic grippers.
Read the paper ↗Spin-offs / Technology Transfer
Vito is founder and president of OmniGrasp, the laboratory’s spin-off, which creates electroactive soft robots to solve automation with difficult objects: food, textiles and biomedical products.